
Table of Contents
- GRASP Lab Facility Tour
- GRASP Lab Facility Snapshot
- GRASP at Levine
- Research Support Facilities at GRASP at Levine
- GRASP at Amy Gutmann Hall
- GRASP at PERCH
- Research Support Facilities at PERCH
- The GRASP Treehouse
- Additional GRASP Research Group Locations
GRASP Lab Facility Tour
GRASP Lab Facility Snapshot
Introduction
The General Robotics, Automation, Sensing and Perception (GRASP) Laboratory is a research facility within the School of Engineering and Applied Science at the University of Pennsylvania and housed within multiple locations. The GRASP Lab’s mission is the creation and integration of knowledge through scholarly research, entrepreneurship and innovation with two facets:
• The design and delivery of robotics education and training of high caliber students to
become leaders in robotics.
• Basic research to advance our fundamental understanding of robots and intelligent
systems and technology development to be a catalyst for innovation and
entrepreneurship in robotics.
The GRASP Lab currently consists of 27 faculty members, 130+ PhD and 200+ Robotics Master’s graduate students, 75+ undergraduate and other Master’s short-term researchers, and numerous full-time or collaborative research staff members and Postdoctoral Researchers. The faculty and students belong to several different SEAS departments, including Computer and Information Science (CIS), Mechanical Engineering and Applied Mechanics (MEAM), and Electrical and Systems Engineering (ESE), thus creating an interdisciplinary lab dedicated to research and education in robotic and intelligent systems. The two main locations of the GRASP Lab provide both space for experiments and significant computing power for modeling and testing as well as electrical and mechanical manufacturing and prototyping machinery. In addition, GRASP’s diverse group of researchers provide expertise to fuse theory, simulation, and practice into working systems.
GRASP at Levine is a vibrant, collaborative environment that fosters interactions between students, research staff and faculty from the CIS, MEAM and ESE departments. Doctoral students are trained in theory and practice and mentored to become leaders in research and education. The graduates of the interdisciplinary Master’s in Robotics program are uniquely equipped to face research and development challenges of the fast-growing robotics industry. Undergraduate students take introductory courses in robotics, pursue independent studies, and conduct research in robotics, computer vision and machine learning.
The GRASP Lab space is comprised of the following research spaces in the Levine Hall, Towne Building, and Moore School Building:
Research/laboratory space (sq ft)
Levine 266 – 825 sq. ft
Levine 403 – 3,934.72 sq ft
Levine 404 – 500.370 sq ft
Levine 457 – 1,286.19 sq ft
Levine 461 – 802.78 sq ft
Levine 463 – 640.84 sq ft
Levine 464 – 235 sq ft
Levine 465 – 802.78 sq ft
Moore 103 – 800 sq ft
Towne 170A – 869.58 sq ft
Towne 170B – 831.20 sq ft
Office Space (sq ft)
Levine 459 – 177.15 sq ft
Levine 460 – 114.99 sq ft
Levine 462 – 115.16 sq ft
Levine 466 – 115.16 sq ft
Levine 468 – 114.99 sq ft
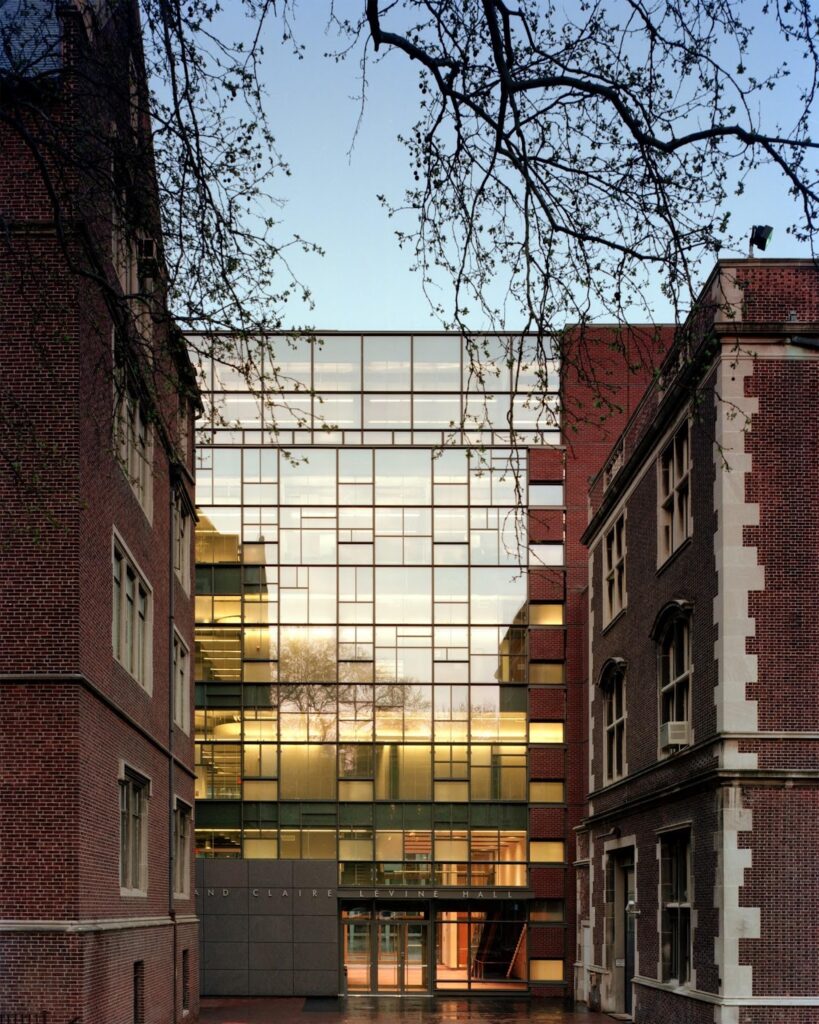
Figure 1: Levine Hall at the School of Engineering and Applied Science (SEAS) and where the main GRASP Laboratory along with smaller associated research labs are located.
Subsidiary Research Groups within the GRASP Lab at Levine
The GRASP Lab at Levine is composed of eight main subsidiary research groups: the Autonomous Manipulation @ Penn (AMP) Lab, the Dynamic Autonomy and Intelligent Robotics (DAIR) Lab, Figueroa Robotics Lab, the Janus Intelligent Robots Lab (JIRL), the Lifelong Machine Learning Group, the Perception, Action, & Learning Group (PennPAL), the Penn Computer Graphics Lab, and the Sung Robotics Lab (in alphabetical order). The GRASP Lab at Levine also hosts the research group of our primary faculty member Jianbo Shi.
The Autonomous Manipulation @ Penn (AMP) Lab is focused on enabling robots to perform long-horizon, contact-rich manipulation tasks in everyday environments. It is housed in an 802.78 square foot dry laboratory space in Levine Hall on the main University of Pennsylvania campus that adjoins a 640.84 square foot experimental laboratory shared with collaborating research groups in GRASP. The AMP Lab’s equipment includes three desktop PCs with GPUs, a Franka Emika FR3 manipulator in the main laboratory space, and a MarkForged Onyx Pro 3D printer that is stored in the shared GRASP laboratory space.

Figure 2: The Autonomous Manipulation @ Penn (AMP) Lab’s location at Levine Hall
The Dynamic Autonomy and Intelligent Robotics (DAIR) Lab is focused on the development of autonomous capabilities for both robotic manipulation and legged locomotion. The lab specializes in enabling robots to more quickly and safely interact with dynamic environments, encompassing algorithmic problems in modeling, control, planning, and learning. It is housed in an 802.66 square foot lab space within the Levine Hall building on Penn’s main campus, adjoining a 640.84 square foot experimental space shared with collaborating research groups in GRASP. The DAIR Lab’s space contains nine computing workstations, with modern GPUs, for algorithmic and simulation development. For manipulation experiments, the lab contains a TriFinger robot hand and three robot arms: a Franka FR3, Franka Panda, and UR10. The lab also contains an Agility Robotics Cassie bipedal-legged robot supported by a two-dimensional gantry system installed in the lab.

Figure 3: The Dynamic Autonomy and Intelligent Robotics (DAIR) Lab’s location in Levine Hall.
Figueroa Robotics Lab focuses on studying and developing the physical and perceptual adaptive intelligence necessary for robots to learn from and interact with humans. The goal is to develop robotic technologies that adapt to a wide-range of human capabilities, needs and ever-changing environments; achieving fluid human-robot collaborative autonomy; i.e., when humans and robots collaborate harmoniously. The lab is housed in a 825 square foot lab space in Levine 266 composed of a 666 square foot main lab space (Figure 4.1-4.4) equipped with a 24-camera Optitrack Motion Capture System as well as a small-scale functioning kitchenette for experimentation with assistive robot household applications; and a smaller 159 square foot adjoint lab space (Figure 4.5) where experimental robotic platforms are evaluated. The equipment that is used in this facility includes three redundant 7-DOF collaborative manipulators (two Franka Emika, one KUKA IIWA) with a wide range of payloads (from 2kg-14kg), one OpenArm 1.0 Bimanual Humanoid upper body, and one Unitree R1 Humanoid. During summer two additional collaborative manipulators (Franka Emika) are borrowed from the MEAM labs to experiment on dual-arm experiments. In addition, the lab has a myriad of robotics peripherals and sensors used with these robots which include: one LEAP 4-fingered hand, one QB 4-fingered compliant hand, one Robotiq 2-finger gripper, one Robotiq force/torque sensor, three Botasys force/torque sensors, one Telemed wearable ultrasonic sensor, one Bittium Neurone wet EEG device. The lab also experiments in social navigation with a 4WD All-Terrain Scout 2.0 Mobile Robot from AgileX and one Fetch Mobile Manipulator for indoor social navigation (Figure 4.6). Computational assets include 7 desktop PCs (GPUs: 4 Nvidia RTX 3070,1 Nvidia RTX 3080, 2 Nvidia RTX 3090) and one Bambu lab 3D printer.

Figure 4.1: Figueroa Robotics Lab’s Main Lab Space (666 sq ft) in Levine Hall 266

Figure 4.2-4: Close up of robots featured in Figueroa Main Lab Space, (Figure 4.2 top-left) rescue Randy mannequin (GRASP shared resource), Unitree R1 Humanoid, OpenArm Humanoid Torso, (Figure 4.3 right) KUKA IIWA-14 with functional kitchenette in the background and (Figure 4.4 bottom-left) a dual-arm setup of a Franka Research 3 and a Franka Panda Emika

Figure 4.5: Figueroa Robotics Lab’s location in Levine Hall 266 Adjoint Lab Space (159 sq ft), featuring another dual setup of 2 Franka Research 3 Arms (robots shared by MEAM teaching labs)

Figure 4.6: Mobile platforms belonging to Figueroa Robotics Lab housed in Levine 457, (left) Scout 2.0 robot by Agile X and (right) Fetch mobile manipulator inherited from Kumar Lab
The Janus Intelligent Robots Lab (JIRL) brings expertise from the fields of robotics, artificial intelligence, control theory, and computer vision to the design of intelligent systems that can perceive, reason, and act in complex environments. Along with desk space in Amy Gutmann Hall, the JIRL is housed in a 500.370 sq ft dry lab space in Levine Hall. The space features two advanced computing workstations alongside a high-performance computing cluster equipped with 8x NVIDIA L40 GPUs. Designed specifically for physical experimentation, the lab includes movable gantries to support legged and loco-manipulation robotics. To maintain a focused testing environment, student desks are located outside the lab, adjacent to the PI and fellow robot learning groups. Students use the laboratory space exclusively for running trials. The lab made a significant investment in diverse robotic platforms for agile flight and locomotion. Current hardware includes 15 Crazyflie quadcopters, two quadrupedal platforms (a Unitree Go2 and a Boston Dynamics Spot), and a Unitree G1 humanoid with Dextera Xhands.
The Lifelong Machine Learning Research Group develops autonomous systems that operate effectively in dynamic environments by learning a diverse variety of tasks and continually adapting over their lifetimes. The group’s research addresses fundamental issues of continual learning and transfer across diverse tasks, scalable knowledge maintenance, self-directed learning, adaptation to changes in the environment with guaranteed performance and safety, and interaction with end-users and other agents. These techniques are applied to problems in autonomous service robots and precision medicine.
For experimental evaluation, the group has access to several multi-GPU workstations and a fleet of autonomous service robots that were designed and built at Penn.
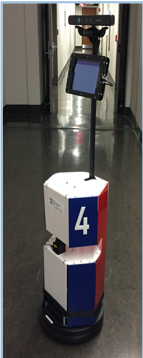
Figure 5: Penn autonomous service robot
The Penn Perception, Action, & Learning (PennPAL) Group, housed primarily in Amy Gutmann Hall with resources in Levine 457, focuses on building general-purpose visually equipped autonomous robots, acquiring and performing many task skills with ease in homes, offices, farms, and hospitals, much like humans. PI Dinesh Jayaraman owns two Franka robot arms, a Sawyer arm, a UR10 arm, 3 WidowX low-cost arms, one LoCoBot mobile manipulator, and one ROBEL low-cost hand robot. The PAL Group’s research includes conducting static manipulation experiments with a Franka arm in the GRASP Lab’s mock kitchen. The group has a Franka arm setup with one static camera mounted beside the arm, and one hand-mounted camera. For mobile manipulation settings, the PAL Group has shared access to a mobile manipulation setup consisting of a Kinova arm mounted on a Fetch mobile base. Other shared GRASP resources that the PAL group has access to includes a Kuka arm, several mobile manipulator robots (including a Fetch and several TurtleBot-based robots), and quadcopters (15 Hummingbirds, 5 Pelicans (Astec), 1 Autel, 3 DJI platforms, and more).
Along with access to the GRASP HPC cluster, the PAL Lab has computational resources such as a cluster of 40 GPUs, spanning L40s, A40s, A10s, and Nvidia RTX 3090s
The Penn Computer Graphics Lab focuses on Computer Graphics, Computer Vision, and AI, with a focus on Neural Scene Representations, Neural Rendering, Human Performance Modeling and Capture, and 3D Reconstruction. The lab is an 800 square feet space located in the SIG Center for Computer Graphics in Moore 103 and houses a multi-view volumetric camera capture stage for capturing human motions and human-object interactions with multiple synchronized cameras. It is composed of four ORX-10GS-123S6C-C 12.3 MP, 68 FPS, Sony IMX253, Color/B2 (9/7) cameras.
Sung Robotics Lab specializes in modeling and design of soft and semi-rigid robots. It is housed in both a 869.58 sq ft dry lab space and a connecting 831.20 sq ft lab space located on the main campus and directly adjacent to SEAS’s main fabrication facilities. The lab contains multiple Linux and Windows workstations for work in simulation and design optimization, as well as workbenches for electronics and mechanical prototyping. A small (2 cu. ft.) motion capture system consisting of 10 Optitrack Flex 13 cameras is used for 0.1 mm precision tracking of deformation at up to 100Hz with 1 cm spatial resolution. The lab also houses an MTS Criterion C41.103 electromechanical test system with 1kN and 50N load cells for materials and mechanisms characterization.
Research Support Facilities at GRASP at Levine
To assist GRASP faculty, staff and students in their research in Levine Hall, there are significant resources available to GRASP members on the fourth floor.
Levine 403: Our main laboratory space contains 58 desks that are assigned to our full-time PhD and postdoctoral researchers. There is a large open space that contains an assortment of tables and chairs to encourage open collaboration. There are 19 ceiling-mounted extension cords spools over the desk area and collaborative areas. There is a shared tool chest containing a variety of tools for students’ hardware needs, including screwdriver sets, English and metric allen keys, levels, plier sets, wire cutters, wire strippers, heat shrink, vice grips, needle file sets, file sets, heat guns, glue guns, wrench sets, socket sets, rotary tools, power drills, drill bit sets, tape and die sets, combination square sets, framing square, counter sink set, dead blow hammer, ball pein hammer, claw hammer, SAE and metric nut driver sets, hack saw, plier set, and dial caliper. There are two HP LaserJet Enterprise M608 printers available for free printing for all lab members. There are 5 large and 7 small storage cabinets, four mobile whiteboards, and a set of 32 lockers from Great Openings.

Figure 6: The collaborative space area of Levine 403, with the assigned desk area behind it.
There is a robotic research space separated by trusses that contains space for three active robotic experiments at a time. Current equipment in this area includes a Franka Panda arm and Ego 4D Aria glasses.

Figure 7: The collaborative space area in Levine 403, with the robot experimentation area behind it.
Levine 457 Vicon Area: This area has an elevated ceiling outfitted with a net and a Vicon Vantage V16 motion capture system with a resolution of up to 16 megapixels (4096 x 4096), capture speed of 120 fps, and +-0.1 mm accuracy.

Figure 8: The high bay and Vicon area in Levine 457.
Levine 457 Mock Kitchen: Levine 457 houses a mock kitchen to be used in robotic experiments to simulate kitchen tasks. The area consists of an operational exhaust hood, refrigerator, and hot plate and non-operational appliances including cabinets, an oven, a dishwasher, stovetop, and sink. The mock kitchen is outfitted with Flex 13 motion capture system consisting of 18 opti-track cameras with resolution of up to 1.3 megapixels, 120 fps, and +-0.2mm accuracy.
Levine 457 Workstations: There are 6 workstations in Levine 457.
Levine 459 Kitchen: The GRASP kitchen features some small tables, chairs, a hot and cold water dispenser, a sink, a Keurig coffee machine with supplies, a refrigerator, and a microwave. It is protected by a punch code and only accessible to GRASP Lab Members.
Levine 463 GRASP Shared Lab Support: The GRASP Shared Lab Space is a 640.84 square foot dry laboratory space located between the Dynamic Autonomy and Intelligent Robotics (DAIR) Lab and Autonomous Manipulation @ Penn (AMP) Lab spaces in Levine Hall. There are two work benches, three storage and tool closets, a whiteboard, and tables. Current equipment includes a Universal Robots UR10 Arm and Franka Emika Arm owned by DAIR Lab and a MarkForged Onyx Pro 3D printer owned by AMP Lab.

Figure 9: The GRASP Shared Lab location at Levine Hall
GRASP Conference Room: The GRASP Lab Conference Room in Levine Hall is a 235 square foot space that is open for meeting reservations for all GRASP research groups. Each GRASP faculty member has access to reserve the space for individual and recurring meetings. The room contains a table and chairs along with two Steelcase Thread freestanding power outlets to accommodate up to 12 meeting attendees. The room also houses a whiteboard, a Viewsonic IFP7550-E1 75” LED display 69.4 x 41.0 x 5.7 monitor with articulating arm display mount, a Logitech meetup webcam for teleconferencing, and an Extron wall-mounted switch for the monitor.

Figure 10: The GRASP Lab Conference Room in Levine Hall
GRASP HPC Cluster: GRASP PIs have access to a shared cluster of about 100 state-of-the-art GPUs (comprising Nvidia A6000s, A10s, A40s, L40(S)s, 4090s, 3090s, 2080Tis, 1080Tis), more than 500 CPU cores, about 2TB of RAM, 27TB SSD storage and 300TB HDD storage.
GRASP at Amy Gutmann Hall: The newly constructed Amy Gutmann Hall building, completed in 2024, is the University of Pennsylvania’s hub for AI and data science research and teaching.
GRASP Faculty members Pratik Chaudhari, Kostas Daniilidis, Jiatao Gu, Dinesh Jayaraman, Antonio Loquercio, Nikolai Matni, George Pappas, Camillo J. Taylor, Rene Vidal, and Mark Yatskar are located in Amy Gutmann Hall. Their research groups have a wide range of computational assets. For example, Dr. Matni’s group has a small GPU cluster, a Quanser Qube, and a Go2 quadruped from Unitree. Dr. Pappas’ group has a Lambda GPU compute node with 2 Nvidia A100 80GB GPU cards, 2 AMD EPYC 9354 32-core CPUs, 384GB of RAM, and 8TB of SSD storage, which functions as part of the larger GRASP HPC Cluster.
The Daniilidis Group specializes in computer vision, both to better understand traditional vision problems and push the boundaries on vision for robotic platforms. As such, we maintain both compute and experimental infrastructure.
To support state of the art computer vision research, the lab maintains a many user SLURM cluster. Compute is serviced with 40 GPUs, 300 CPU cores, 1TB RAM. Persistent data storage is handled by 26TB NVMe and 160TB HDD through network attached storage. Real-time demos are supported by the 3x Nvidia TX-2 and 2x Nvidia Xaviers to run our current methods with FLIR machine vision cameras. In addition to traditional images and processing methods, our group supports neuromorphic hardware, both sensing and computation. On the sensing side, 2x DVS 346s and 2x DVS 240Cs from iniVation provide fully asynchronous event based vision. Our partnership with Intel allows us to bring low power asynchronous computation to event based vision with both physical and remote access to Loihi hardware.
Research robots for our group include a Kuka IIWA, Baxter, and Sawyer. These are complemented by high end desktops that can run the latest perception and planning models to Smart Aviary (shared project with Marc Schmidt’s group in the Biology department):
In the Smart Aviary, a flock of 15 cow birds is monitored with 10 hardware-synchronized FLIR computer vision cameras. The video is recorded for subsequent analysis, working towards fully automated, marker-less tracking and study of the bird’s behavior. Additionally, 24 Behringer microphones record the birds’ songs. The audio sampling of the microphones is synchronized to allow for time-difference-of-arrival algorithms to determine the 3d position of the singing bird. The data is recorded on a server at a shed next to the aviary.
GRASP at PERCH: The Penn Engineering Research and Collaboration Hub (PERCH) is a brand new research facility housed within the Pennovation Center at the University of Pennsylvania. Our facility at PERCH brings researchers and students from across Penn together with collaborators from the private-sector tenants to promote innovative exchange, foster entrepreneurship and economic development and support impactful research and discovery. Pioneering researchers are building autonomous vehicles and robots, developing self-configuring humanoids, and making robot swarms a reality.
The GRASP Lab space is also comprised of the following research lab and machine shop space within the Pennovation Complex (in net sq ft):
Building 450
3rd Floor – 10,000 nsf
1st Floor (design and fabrication facility) – 1,326 nsf
Basement (OMAX water laser jet cutter) – 422 nsf
Building 200
Suite 100 – Prof. Hsieh’s ScalAR Lab – 752 nsf
Building 250
GRASP Treehouse – 5,090 nsf
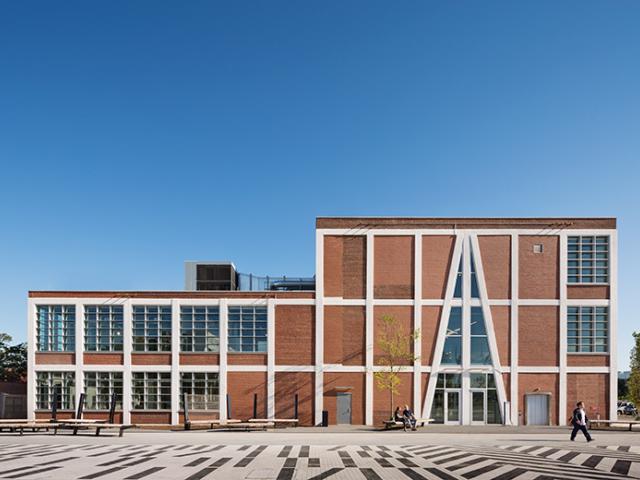
Figure 11: The Pennovation Center is the home of the Penn Engineering Research and Collaboration Hub (PERCH).
Subsidiary Research Groups within the GRASP Lab at PERCH
The GRASP Lab at PERCH is composed of three main subsidiary research groups: the Kumar Robotics Lab, the Modular Robotics Lab (ModLab) and the Scalable Autonomous Robots Laboratory (ScalAR) (in alphabetical order).
The Kumar Robotics Lab is equipped with a large fleet of aerial robots (UAVs), including commercially available platforms, as well as those developed in-house. A diverse array of commercially available robots comprises a fleet of twenty Micro-Aerial Vehicles (MAVs) with varying form factors and advanced autonomous capabilities, ranging from 100 g to 5 kg. The UAV fleet is complemented by a selection of Crazyflie, Aurelia, and Skydio commercial platforms. Kumar Robotics is also actively developing several aerial platforms to suit particular tasks with demanding requirements. All robots are equipped with different onboard sensing and computing modules, permitting autonomous operation both indoors and outdoors (Figure 12.1).

Figure 12.1: UAV platforms developed by the Kumar Lab are shown in order of increasing size and payload capability: brushless Crazyflie (top-left), a 32-g platform with a wind sensor mounted; the Dragonfly (top middle), a palm-sized UAV designed for use in robust, collision-resistant swarms; the Neurofly (top-right), a small-sized platform optimized for long-duration indoor navigation, equipped with both RGB-D and event cameras; the Falcon 250 (middle-left and center), a medium-sized platform optimized for small-footprint indoor navigation and exploration; the Kestrel (middle-right), a slightly larger platform that is capable of both indoor navigation and outdoor high-altitude flights; the Falcon 4 (bottom), a general-purpose platform optimized for long flight times and low vibrations for stable flight.
In addition to aerial platforms, Kumar Robotics houses a variety of wheeled and legged robots for ground based operations, including three Clearpath Jackals and six custom-built Scarab robots. Their different modalities support a range of experiments, spanning indoor, outdoor, and underground environments. The Scarabs are differential-drive robots equipped with multiple sensing modalities: LiDAR, RGB-D cameras, and motor encoders. The small size and compact form factor make them ideal platforms for indoor multi robot experiments. Complementing them, the Jackals, with a similar sensor suite, are rugged, outdoor ready robots. Both platforms offer impressive computational capabilities, with the Jackals notably featuring NVIDIA A4000 GPUs for AI inference applications (Figure 12.2).
Furthermore, having teams of these platforms enables us to research and implement multi-agent algorithms. Finally, the lab has two Boston Dynamics Spot robots with arms, and several Unitree robots (Figure 12.3).

Figure 12.2: (Top) The Scarab robot is a research platform developed in-house to serve as a test bed for large multi-robot teams. It contains a powerful CPU to facilitate real-time planning, state estimation, and mapping algorithms. (Bottom) Clearpath Jackals with custom-designed sensor tower featuring Ouster LiDARs, Mesh Radio modules, and multiple cameras. Coupled with the Falcon 4, these robots have been used simultaneously for heterogeneous, multi-robot experiments.

Figure 12.3: (Left) The Boston Dynamics Spot robot is equipped with an arm, RGB-D and LiDAR sensors, and a Mesh Radio module. This platform has been used in heterogeneous robot collaboration experiments and enables mobile manipulation in large-scale and unstructured environments. (Right) The Unitree robot is a wheeled quadruped that combines the fast mobility of a wheeled platform with the robust traversability of a quadruped. This robot is also equipped with a sensor tower comprising a LiDAR and four RGB cameras that provide a 360-degree field of view.
In addition to the physical robot platforms, our lab maintains multiple workstations for simulations, and a server rack for training large models and handling compute-intensive tasks. The rack includes an NVIDIA DGX-1, a NAS with 288 TB raw storage, and a server equipped with 8 NVIDIA L40S GPUs, 1.5 TB of RAM and 2xAMD EPYC 9684X processors (Figure 12.4).

Figure 12.4: Kumar Robotics Server rack shown above. The three subsystems are interconnected with 100 Gbps Direct Attach Copper (DAC).
The lab has access to the Penn Advanced Research Computing Center (PARCC) and the Betty Holberton Supercomputer, a transformative infrastructure now ranked 8th fastest among US academic institutions. PARCC features a total of 248 B200 GPUs in 31 DGX B200, as well as 2.5 PB of high speed SSD-based storage. PARCC opens to all users on March 15th, 2026. PARCC delivers centralized HPC and AI infrastructure with robust systems support and research consulting. Penn is committing substantial resources to subsidize access, enabling researchers to use advanced computational capabilities far below true cost, dramatically reducing financial barriers to innovation.
ModLab includes a large variety of modular robot systems currently used and reused in a variety of experimental systems. The lab has approximately 100 CKBot modules of the V1.1 another 100 CKbot V1.2 modules, plus another dozen prototypes of specialized modules that include grippers, fast dynamic modules, continuous modules, smart-camera modules etc. In addition, ModLab has created robots ranging from the world’s smallest self-powered flying robot about 2cm, as well as large self-assembling truss robots designed to hold up buildings.
This part of the lab also has equipment for manufacturing and testing small flying devices including a variety of high-speed motion capture imaging devices, stereo 3D RGBD cameras, miniature 6DOF force/torque sensors. In addition, ModLab has a netted HTC vive tracking area with minimized HVAC cross flow and structures to simulate small downwash testing interactions.
To complement the industrial 3D printers in PERCH, Modlab has five small FDM 3D printers and two Formlabs 3D printing stations highly suited for rapid prototyping small robot components. In addition, the lab includes a stereo microscope for fine assembly, electronics prototyping, soldering and SMD re-work stations, and fine metalworking equipment for creating and testing small electromechanical systems. The lab is also set up with a full set of hand tools, and stocked with raw materials and an array of discrete electronics, sensors and actuators for electromechanical prototyping.

Figure 13: A Modlab SMORES-EP (Self-assembling MOdular Robot for Extreme Shapeshifting – Electro Permanent) is capable of rearranging its modules in all three classes of reconfiguration; lattice style, chain style, and mobile reconfiguration.
ScalAR (Scalable Autonomous Robots Laboratory) developed and maintains the multi-robot Coherent Structure Testbed (mCoSTe) – the first marine multi-robot testbed capable of creating controlled ocean-like flows. The mCoSTe consists of 10 Autonomous Surface Vehicles (ASVs) and three experimental flow tanks: a Low Reynolds number (LoRe) Tank, a High Reynolds number (HiRe) Tank, and a Multi-Robot (MR) Tank. The LoRe, HiRe, and MR Tanks are respectively 10 cm2 x 2 cm, 3600 cm2 x 30 cm, and 10.8 m2 x 1 m in size. Flow fields generated in each of these tanks can be tracked using particle imaging velocimetry (PIV) and/or particle tracking velocimetry (PTV). The flows in the mCoSTe tanks are patterned after common ocean circulation models that provide a kinematic description of both time-independent and time-varying flows and allows the explicit modeling of uncertainty and noise. The mCoSTe ASVs include 100 g vehicles equipped with inertial measurement units (IMUs) and wifi radio capabilities and 110 g vehicles equipped IMUs, wifi, and onboard flow sensors. Localization for the ASVs is provided by an external motion capture system.
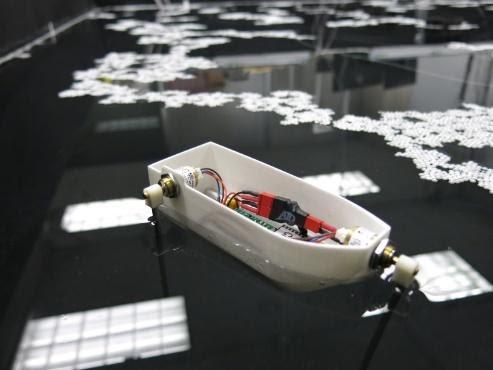
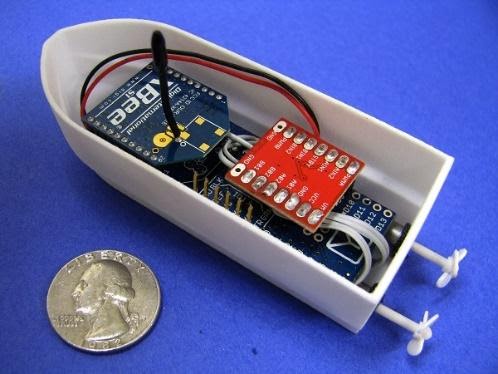
Figure 14.1: The mCoSTe ASVs.
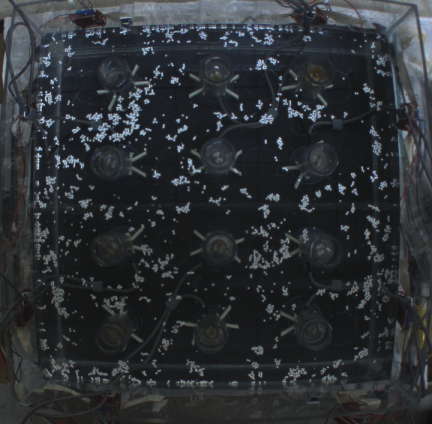
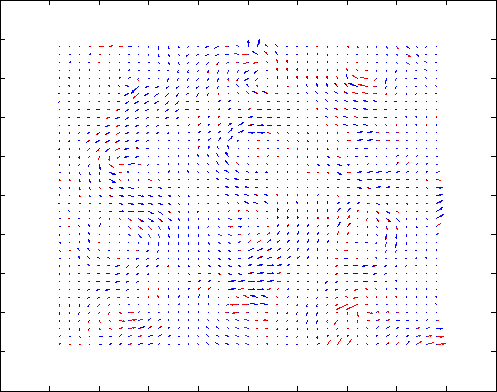
Figure 14.2: (Left) Overhead view of the experimental setup of the HiRe flow tank with 12 driven cylinders for creating gyre-like flows. (Right) PIV extracted surface flow field.
ScalAR also houses one Clearpath Robotics, Inc. Heron autonomous surface vehicle (ASV) equipped with GPS, onboard camera, IMU, and bathymetry sensor.
Research Support Facilities at PERCH
To assist GRASP faculty, staff and students in their research at PERCH, there are significant resources available in the Pennovation Center. These include various open common areas throughout the building to provide a friendly and modern working environment. Specific to PERCH are computer workstations and indoor and outdoor testing facilities. Also integral to the GRASP Lab at PERCH is the Design and Fabrication facility that is housed on the first floor of the Pennovation Center, which allows for prototype development and manufacturing.
Workstations
The GRASP Lab at PERCH features a common area with workstations that can house approximately sixty researchers and students in a friendly and modern working environment.
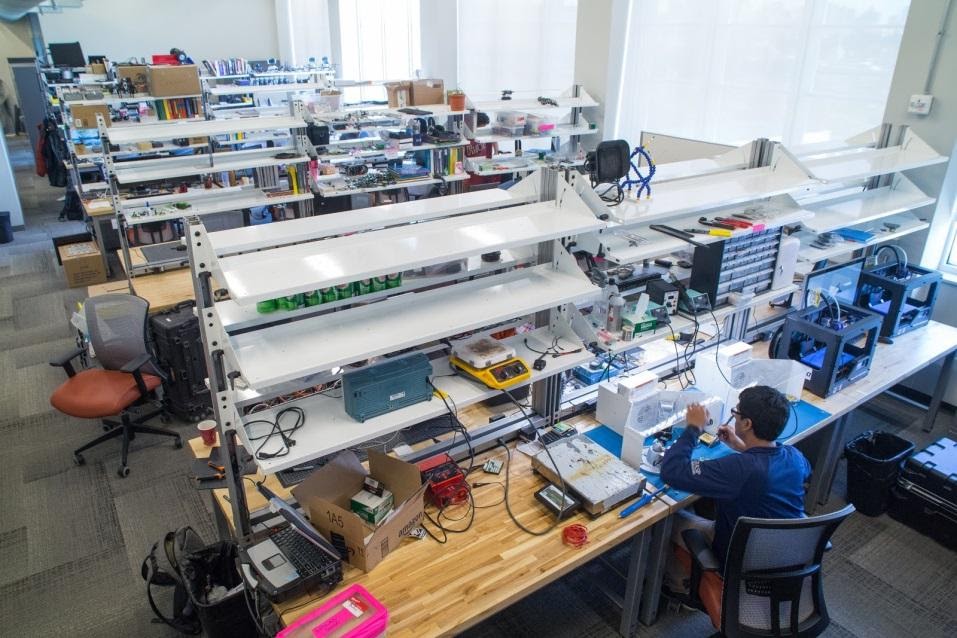
Figure 15: Modern workstations with ample lighting, power and networking capabilities are available for PERCH researchers on the 3rd floor of the Pennovation Center.
Indoor Testing Area
This consists of a 88 ft. L x 22 ft. W x 15 ft. H indoor area used for experimentation with unmanned aerial vehicles, ground wheeled robots and humanoids. This space is instrumented with 20 high-resolution Vicon Advantage V16 motion capture cameras (https://www.vicon.com/products/camera-systems/vantage) that allow motion capture at over 100 Hz with mm accuracy.
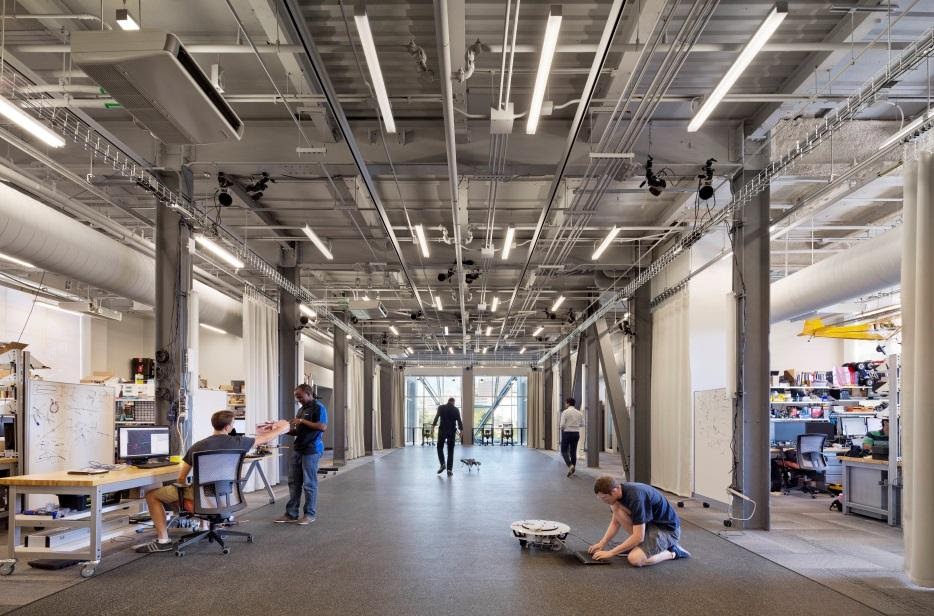
Figure 16: PERCH indoor testing area that allows experimentation with unmanned aerial vehicles, ground wheeled robots and humanoids
Outdoor Testing Area
This consists of a 100 ft. L x 50 ft. W x 50 ft. H outdoor netted area instrumented with an all-weather motion capture system comprised of 28 high resolution Qualisys Opus 700+p cameras (http://www.qualisys.com/cameras/oqus/). This space allows testing of aerial and ground vehicles in an outside laboratory setting.
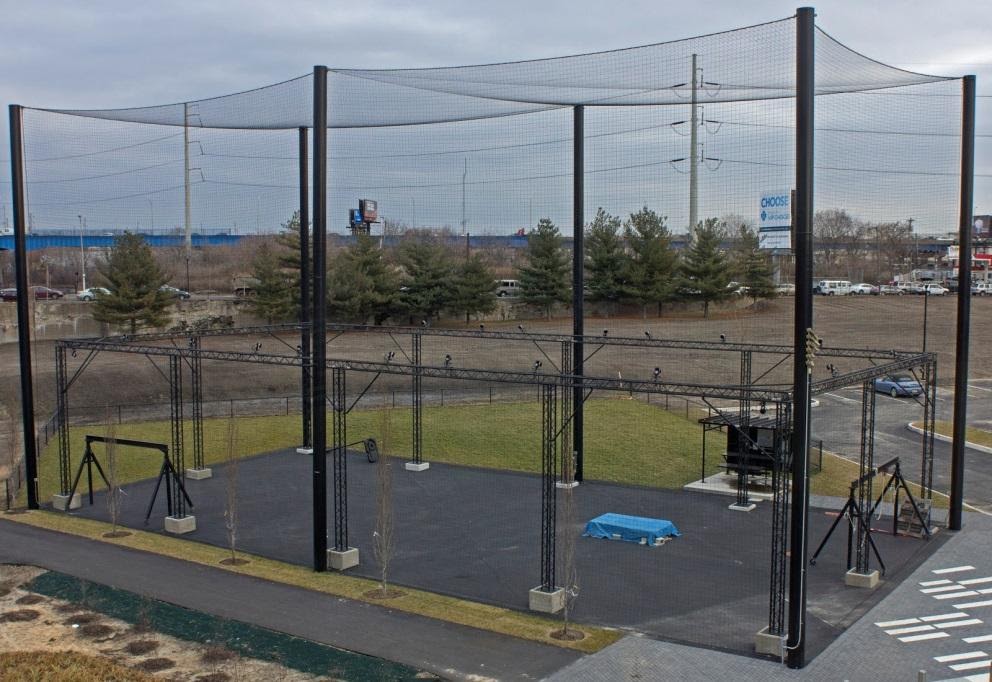
Figure 17: PERCH outdoor testing area that allows experimentation with aerial and ground vehicles and includes a 28 camera all weather motion capture camera system.
PERCH Design and Fabrication Facility
Integral to the GRASP Lab at PERCH is the Design and Fabrication Facility that is located on the first floor of the Pennovation Center. With a unique blend of conventional design and fabrication machinery along with rapid prototyping equipment, this facility allows development of quick turnaround prototypes or final end products. Technical staff are available to assist PERCH researchers by providing engineering and design assistance as well as prototype development, general fabrication, and assembly. The facility size is 66 ft. L x 22 ft. W and includes various types of fabrication equipment. A detailed description of these resources follow.
Additive manufacturing equipment includes FDM 3D printing capabilities for fast part manufacturing and prototyping.
| Stratasys FORTUS 380mc Build envelope of 14 in. x 12 in. x 12 in Layers thicknesses of 0.005 in. thru 0.013 in Materials that can be printed include ABS Part accuracy of +/- 0.005 in. | 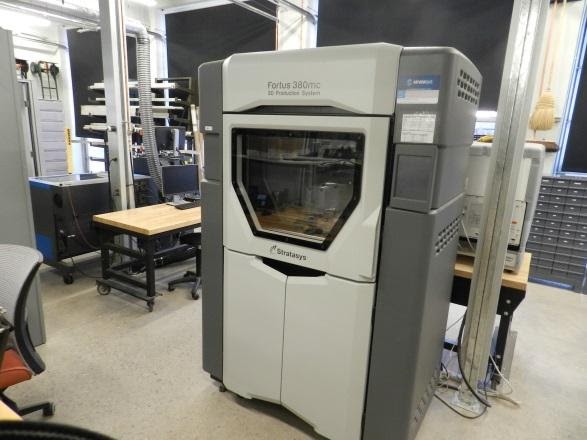 Figure 18.1: Stratasys FORTUS 380mc |
There are two CO2 laser cutting systems available for 2D cutting and engraving. These systems allow cutting of various plastics as well as engraving on plastics or metal. There are two systems available: ULS PLS 6.75 Laser Platform and ULS PLS 4.75 Laser Platform. Both have the same wattage ratings but vary in the size of the build envelope.
| ULS PLS 6.75 Laser Platform Build envelope of 32 in. x 18 in. x 9 in Power 75 Watt Materials that can be cut include ABS, Acrylic, and MDF. Laser cutting kerf of 0.007 in. ULS PLS 4.75 Laser Platform Build envelope of 24 in. x 18 in. x 9 in Power 75 Watt Materials that can be cut include ABS, Acrylic, and MDF. Laser cutting kerf of 0.007 in. | 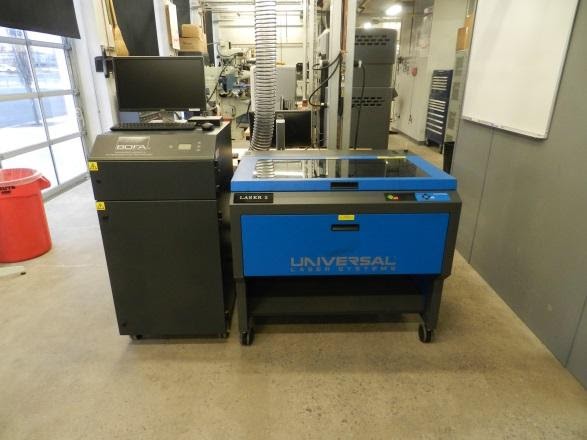 Figure 18.2: ULS PLS 6.75 Laser Platform Figure 18.3: ULS PLS 4.75 Laser Platform |
An Abrasive Waterjet Cutting System is available for parts manufacturing. This compact, high-precision Omax 2626 machine will allow various types of materials to be cut in varying thicknesses.
Omax 2626 JetMachining Center Build envelope of 29 in. x 26 in. x 8 in 30 HP pump Materials that can be cut include plastics, aluminum, steel, etc. at various thicknesses. Accuracy +/- 0.001 in. | 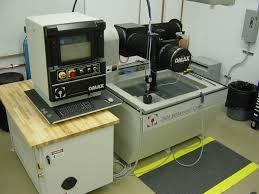 Figure 18.4: Omax 2652 JetMachining Center |
Conventional machining equipment includes: TRAK bed mill with CNC or manual capabilities, TRAK lathe with CNC or manual capabilities, and a Victor manual knee mill.
TRAK Bed mill with ProtoTRAK CNC controller Travels X, Y and Z: 31 in. x 16 in. x 23.5 in. Table Size: 49 in. x 9 in. 3 HP spindle motor.R8 spindle taper. ProtoTRAK control with 2 or 3-axis CNC, 3-axis DRO mode. Can run conversational language, G-code, or CAM software. | 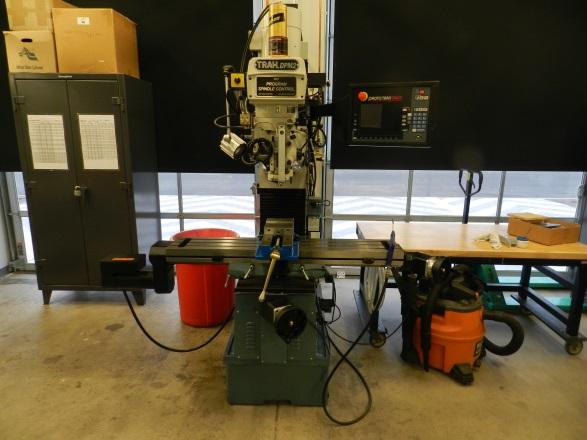 Figure 18.5: TRAK DPM SX2P bed mill with CNC or manual capabilities. |
TRAK Lathe with ProtoTRAK CNC controller 16 in. swing over bed, 30 in. between centers. Operate in CNC or manual mode. ProtoTRAK control with 2 axis CNC, 3-axis DRO mode. Can run conversational language, G-code, or CAM software. | 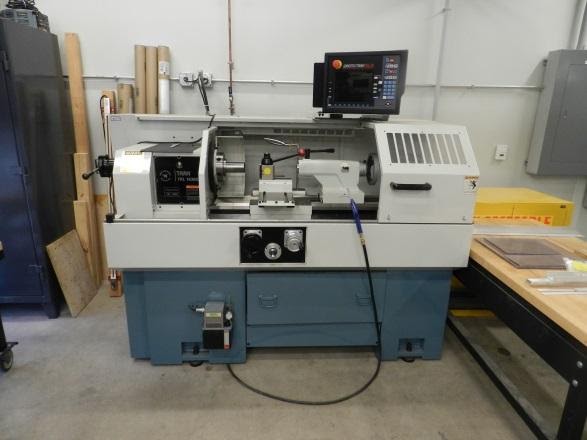 Figure 18.6: TRAK TRL 1630SX lathe with CNC or manual capabilities. |
Victor Knee Mill Travels X, Y and Z: 40 in. x 16 in. x 16 in. Table Size: 54 in. x 10 in.3 HP spindle motor. R8 spindle taper. 2-axis DRO. Power feed on X axis. | 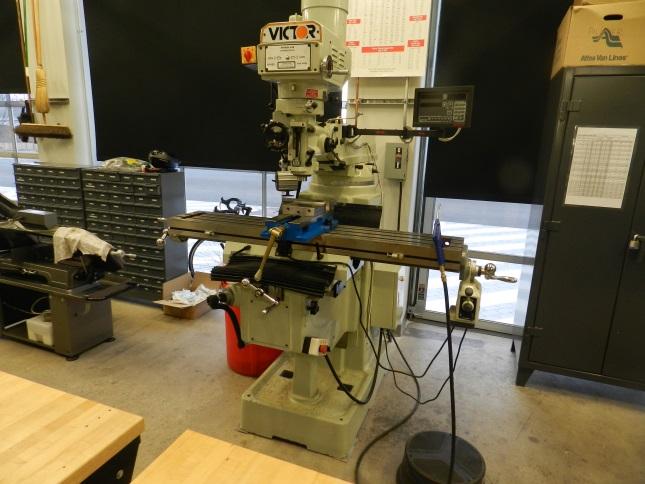 Figure 18.7: Victor JF-4VS Vertical Knee Mill. |
Assortment of general fabrication machines include: vertical band saw, horizontal band saw, bench top drill press, free standing drill press, belt sander, and pedestal grinder. An assortment of hand tools and measurement instruments are also available for use.
DoALL Veritcal Bandsaw Throat, band to column: 20 in. Max. work height: 13 in. Variable speed: 30 to 320/550 to 5,500 fpm. Table size: 26 in. x 26 in. | 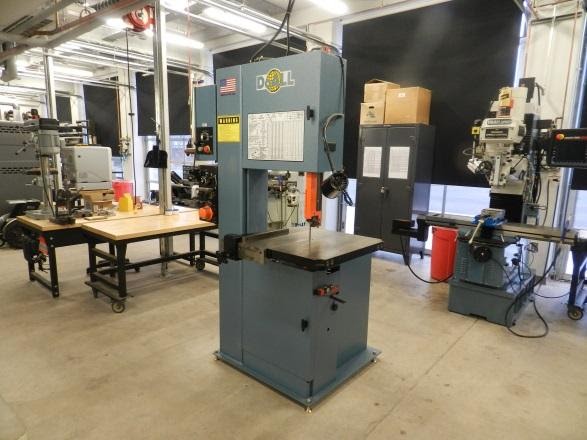 Figure 18.8 DoALL 2013-V3 Vertical Bandsaw. |
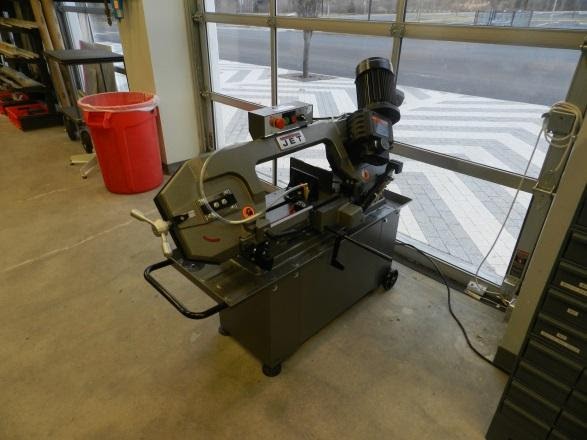
Figure 18.9: JET 8 in. x 14 in. Horizontal Bandsaw
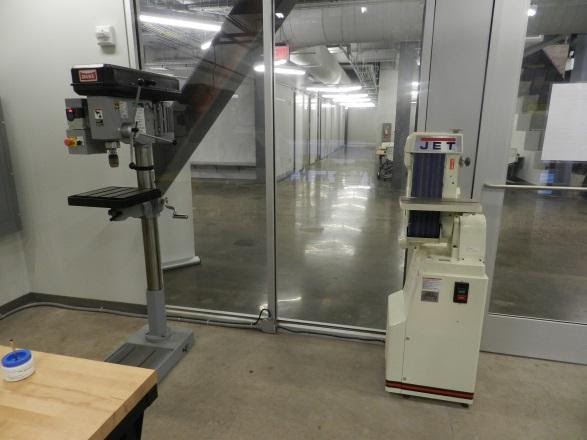
Figure 18.10: Dake Drill Press and JET Belt Sander
The GRASP Treehouse: The GRASP Treehouse, located in Building 250 at Pennovation, is a research space dedicated to ROBO MSE capstone projects and other GRASP lab research, events, and collaboration. The 5,090 net square foot facility houses a main research area, a multi-purpose room, two offices, and a small conference room. The main research area is a lab space with four lab bench sections consisting of a total of 16 work desks, all facing each other to encourage collaboration. There are 3 additional desks against one of the walls, as well as a row of 5 large storage cabinets capable of storing large robots, shelving units intended for robot and project storage, four small cabinets, and a kitchenette for lab member use. There are 12 ceiling-mounted extension cord spools, and a color printer, scanner, and copier. The research area is outfitted with a wall-mounted Samsung BEC-H Series 75″ UHD 4K HDR Commercial Monitor, 12 wall-mounted Q-SYS NC Series PTZ conference cameras, and a Shure Linear Array Microphone MXA710.

Figure 19: The research area at the GRASP Treehouse.
The multi-purpose room is intended to be a flexible space to host any GRASP-related events including workshops, seminars, new student orientations, ROBO capstone and thesis presentations, and more. The room is equipped with an AV system consisting of Samsung QM85R-B 85″ LED Display mounted on a Salamander X-Large Electric Lift Mobile Display Stand with a camera shelf, keyboard stand, a small shelf, a vertical rack mounting bracket, equipment storage cover, and retractable CAT6 and regular cable reels.
The video system in the multi-purpose room includes a Q-SYS NV-32-H (Core Capable) Native Network Video Endpoint for Q-SYS, a Mersive Solstice Pod SP-8000-E1 wireless group collaboration device, and 12 wall-mounted Q-SYS NC Series PTZ conference cameras. The audio system in the multi-purpose room includes a Sennheiser wireless lavalier microphone set, wireless handheld microphone set, a 2 way antenna splitter/divider, and a QSC MP-A40V power amplifier. The room is outfitted with 8 QSC AC-C8T 8 Inch 2-Way ceiling speakers and a Sennheiser beamforming ceiling array microphone with two Dante and one analog audio output. The control system consists of a Q-SYS Core 110f v2 processor.

Figure 20: The multi-purpose room at the GRASP Treehouse.
The small conference room is outfitted with a wall-mounted Samsung BE65T-H 65″ Commercial TV with a Logitech MeetUp HD Video and Audio Conferencing System, a Mersive Solstice Pod SP-8000-E1 wireless group collaboration device, INOGENI’s TOGGLE USB 3.0 PRO AV switcher, and a Liberty HDMI and USB wall plate.
The reception area is outfitted with a wall-mounted 65″ Class Samsung Neo QLED 4K QN90D TV that has a C2G 2-Port HDMI Switch and a Liberty HDMI and USB wall plate. Some of the robotic equipment at this facility include a Baxter robot, a Universal Robotics UR10e collaborative robot, and a large format 3D printer.
Additional GRASP Research Group Locations
The Nanorobotics Lab is focused on state-of-the-art fabrication and metrology for robots too small to see by eye. The lab is 800 square feet and housed in the Singh Center for Nanotechnology. Central to the lab area are four microscope probe stations specifically designed for testing small scale robots. One probe station is built around an upright microscope and designed to support in situ electrical and mechanical probing. It has two computer-controlled micromanipulators, a mobile stage, a hyperspectral imaging camera and a range of illumination light sources spanning UV to NIR. The second probe station is designed for light-based manipulation and control. Built around an inverted microscope, it features a galvo-steered laser, multiple laser sources for illumination under different wavelengths of light, and a liquid crystal spatial light modulator for holographic light projection. This inverted also supports experiments with biological cells thanks to an on-scope cell incubator. In addition, the lab houses a range of other microscale tools including low noise amplifiers, multi-axis Helmholtz coils, microinjectors, and two wet-chemistry hoods. The lab is located down the hall from the Quatrone nanofabrication facility, a 10,000 square foot cleanroom where Nanorobotics Lab members carry out their in-house fabrication work.
The Rehabilitation Robotics Laboratory is directed by Dr. Michelle Johnson. Dr. Johnson is a professor with a primary appointment in the department of Physical, Medicine and Rehabilitation (PM&R), School of Medicine, and secondary appointments in the School of Engineering and Applied Science in the departments of Bioengineering and Mechanical Engineering and Applied Mechanics. Her office and lab are located at the Penn Medicine Rittenhouse location. This location provides easy access to administrative support services and to the therapy offices. The lab is about 1400 square feet and is dedicated to the design, development and therapeutic use of novel, affordable, intelligent robotic/mechatronic assistants. The lab houses 6 desktops and 5 laptops dedicated for development use with office spaces for graduate students. The lab has several robotic equipment: Omni Robot, Vgo, Baxter, and other sensing equipment. Custom robotic/mechatronic systems developed are bi-ADLER (Two 5 degree of freedom robots), electromechanical systems: 2 Flo social robots with mobile bases, haptic Robots, TheraDyad Robots, 2 THEAbots, NeuroNinja, REHAB CARES robot gym, and fMRI safe devices such as a glove, orthosis, and a hand bike. The lab houses several clinical assessment tools such as Box and Block, Groove Peg Board etc. The lab houses several computers with the software needed to perform needed data collection and analyses: Matlab, Python, Microsoft visual studio.net, etc. The lab has small electronics prototyping equipment such as soldering mechanical prototyping equipment such as 3D printers for rapid prototyping of small parts. Dr. Johnson currently supervises several graduate and undergraduate students from multiple departments in engineering, bioengineering, and robotics. Her lab includes two locked cabinets to protect research source data and has network access via hard-wire or wireless connections. She also works closely with residents and medical students in the department of PM&R.