
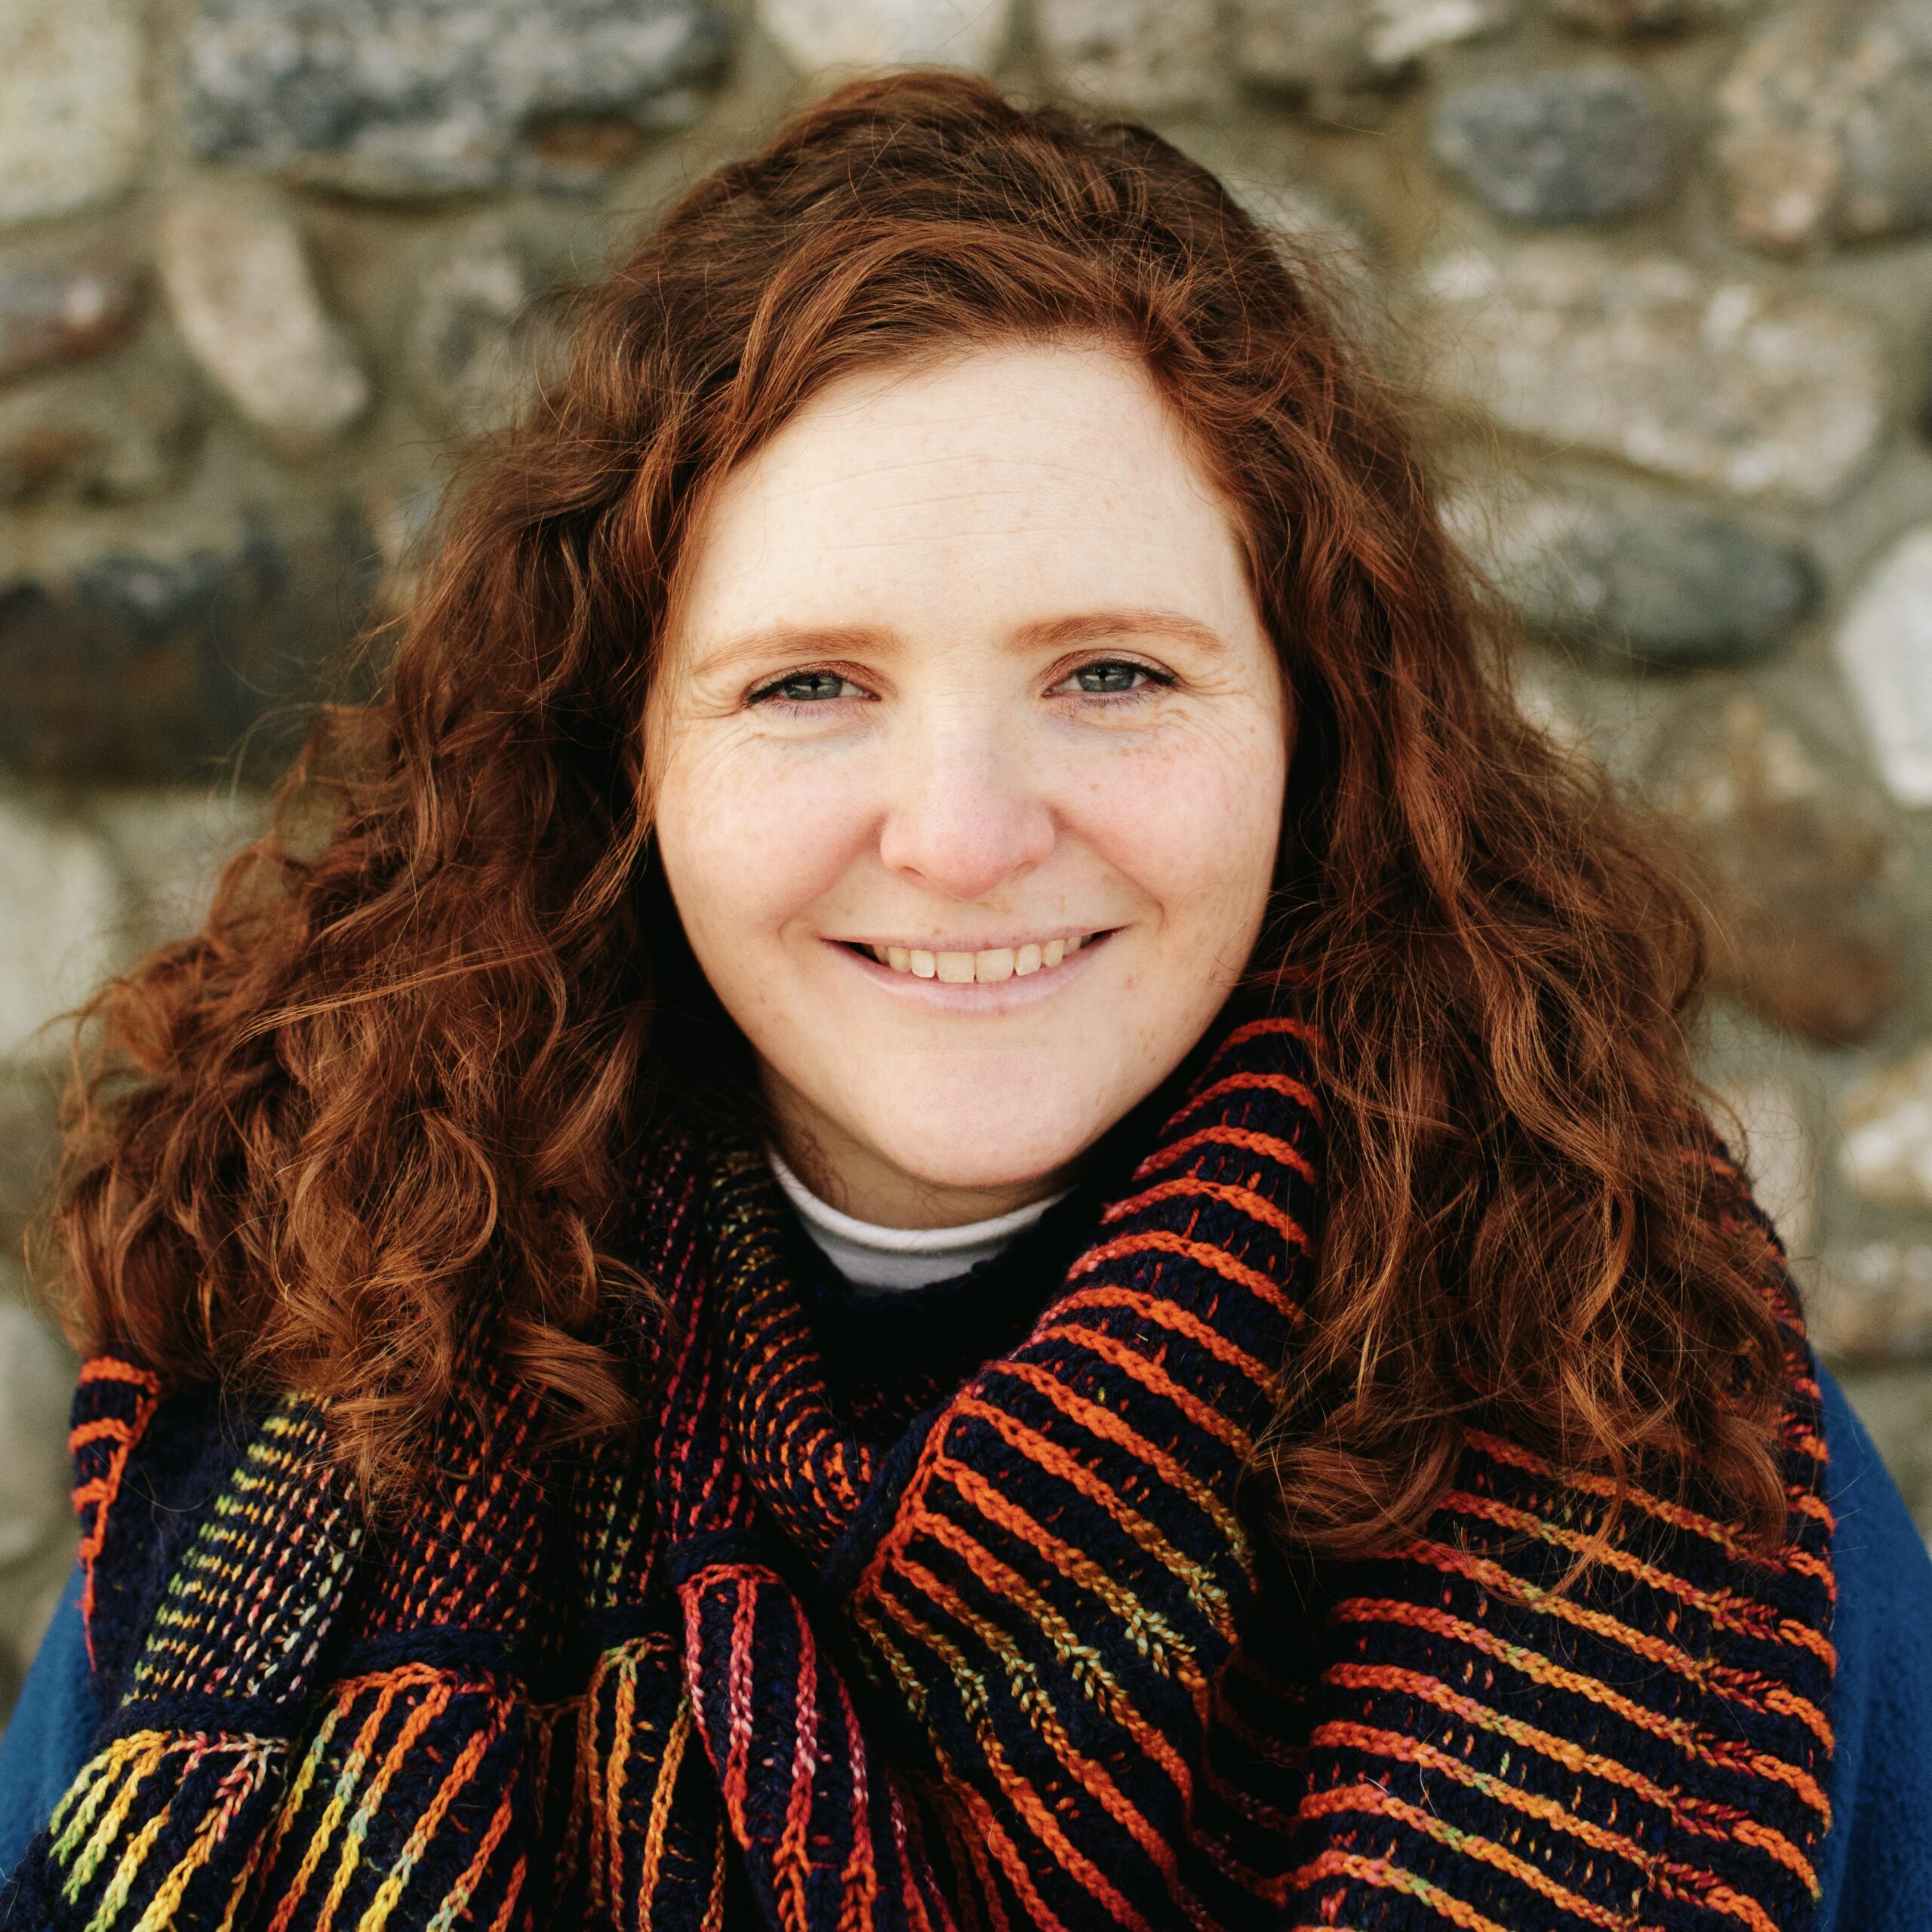
Victoria Edwards (She, Her, Hers)
PhD, MEAM '25 - Assistant Professor, University of New Hampshire
Victoria Edwards is a member of the ScalAR Lab working on deploying robot teams in complex and unstructured environments. Victoria completed her bachelor’s degree in computer science and mathematics at Colby College, and her Masters in Robotics at the University of Michigan.
Research Groups
Projects
Publications
Multi-robot Multi-source Localization in Complex Flows with Physics-Preserving Environment Models
Publisher arXiv
Publisher International Conference on Autonomous Agents and Multiagent Systems
Flow-Based Localization and Mapping for Multi-Robot Systems
Publisher IEEE Robotics and Automation Letters
A Macroscopic Ensemble Modeling Approach to Collaborative Task Assignment in Dynamic Environments
Publisher DARS
Learning and Leveraging Features in Flow-Like Environments to Improve Situational Awareness
Publisher IEEE
News
GRASP News
Robots in the Reading Room: GRASP Lab Brings Hands-On STEM to Roxborough Library
April 21, 2025
Student News
The 2024 SEAS Graduate Awards Ceremony Shines a Spotlight on GRASP Student Achievements
May 28, 2024